Please share research on the real-time hazard detection system………….
Latest Hyperspectral Satellite Sensors and Multi-Hazard Detection
[ The copyright © 2026 Z M Sajjadul Islam, Advisor, Multi-Hazard Early Warning System Design and Implementation Center (MHEWC – www.mhewc.org ). All rights reserved. Any material quoted, reproduced, adapted, or extracted from this study must be properly cited and attributed to the author. Please call at +8801711979179, Email: zmsajjad@gmail.com ]
The principal technological advance is not a single “all-hazard” hyperspectral sensor. It is the emergence of a satellite system of systems that combines:
- Hyperspectral infrared atmospheric sounders;
- Visible-to-shortwave-infrared imaging spectrometers;
- Ultraviolet–visible atmospheric-composition spectrometers;
- Thermal imagers;
- Passive microwave radiometers;
- Precipitation radar;
- Synthetic-aperture radar;
- Lightning imagers;
- Scatterometers, altimeters and GNSS radio occultation; and
- Ground observations, forecasting models and AI-based analytics.
Hyperspectral instruments are exceptionally good at determining what a cloud, gas, mineral, vegetation canopy, water body or surface material is made of. However, they do not directly measure every hazard. Extreme rainfall, floods, earthquakes and tsunamis require complementary radar, microwave, seismic, hydrological and ground-observation systems.

- What makes a sensor hyperspectral?
A conventional multispectral instrument normally observes several broad wavelength bands. A hyperspectral instrument divides the spectrum into hundreds or thousands of narrow, closely spaced channels. Each pixel therefore contains a nearly continuous spectrum: where represent location and represents wavelength. The result is a three-dimensional spectral data cube. Different materials and gases absorb or reflect radiation at distinctive wavelengths, producing identifiable spectral fingerprints. These fingerprints can reveal: Atmospheric temperature and humidity at different heights; Water vapour transport and atmospheric instability; Methane, carbon dioxide, ozone, sulphur dioxide and other gases; Smoke, volcanic ash, aerosols and mineral dust; Vegetation pigments, canopy water content and physiological stress; Soil minerals, organic matter and moisture; Snow grain size, dust contamination and albedo; Burn severity and post-fire vegetation recovery; Water quality, suspended sediment and algal pigments; and Surface minerals associated with unstable slopes or volcanic activity.
- Main categories of hyperspectral satellite sensors
Sensor family | Typical observation | Principal value | Important limitation |
Thermal-infrared atmospheric sounder | Thousands of IR channels, generally 4-14 km spatial resolution | Vertical temperature, humidity and trace-gas profiles; pre-convective instability | Does not directly measure surface rainfall |
VSWIR surface-imaging spectrometer | Approximately 0.38–2.5 μm; typically 30–60 m pixels | Vegetation, soil, minerals, water, burn scars and gas plumes | Normally requires daylight and relatively cloud-free conditions |
UV–VIS–NIR–SWIR atmospheric spectrometer | Kilometre-scale pixels | Air pollution, volcanic SO₂, ozone, aerosols, methane and carbon monoxide | Mostly column measurements; cloud and sunlight constraints |
Ocean-colour hyperspectral sensor | UV, visible and near-infrared, with some SWIR bands | Phytoplankton, water quality, harmful algal blooms and aerosols | Coarser resolution and field validation requirements |
Fluorescence spectrometer | Very fine bands around oxygen absorption features | Photosynthetic activity and early plant stress | Usually moderate spatial resolution and not an emergency-response sensor |
- Latest atmospheric hyperspectral sensors
FY-4C GIIRS-3 – China
FY-4C, launched on 27 December 2025, is the newest geostationary satellite carrying a hyperspectral infrared sounder. Its upgraded GIIRS instrument provides:
- Approximately 1,728 spectral channels;
- Longwave and midwave infrared coverage;
- Spectral resolution of about 0.625 cm⁻¹;
- Approximately 8 km nominal infrared resolution, with 4–8 km capability;
- Hourly coverage of a roughly 5,000 × 5,000 km regional domain; and
- Temperature, humidity, atmospheric-instability and trace-gas retrievals.
As of August 2026, FY-4C’s GIIRS, imager and lightning instruments remain under testing, while FY-4B’s GIIRS is operational at 105°E. This makes FY-4B particularly relevant to South Asia, including Bangladesh. China’s official satellite-status page and GIIRS specifications provide current details.
MTG-S1 Infrared Sounder – Europe
MTG-S1 was launched on 1 July 2025. The satellite completed its in-orbit commissioning on 2 July 2026 and was moved to its operational position at 0° longitude. Full MTG system commissioning is planned for completion by October 2026.
Its Infrared Sounder provides: More than 1,700 thermal-infrared channels; Longwave and midwave infrared observations; 4 × 4 km spatial resolution; 0.625 cm⁻¹ spectral resolution; Full-disc scanning every 60 minutes; Local-area scanning capability every 15 minutes; and Three-dimensional temperature, humidity, wind and trace-gas information.
Its most important early-warning function is detecting moisture convergence, unstable atmospheric layers and rapid changes preceding severe convective storms. It complements the rapid imagery and lightning measurements from MTG-Imager satellites. ESA’s MTG-S1 commissioning update and Infrared Sounder specifications describe the capability.
IASI-NG on Metop-SG-A1 – Europe
Launched on 13 August 2025, IASI-NG is the next generation of Europe’s polar-orbiting infrared atmospheric sounder. Its features include:16,921 spectral samples, compared with 8,461 on the earlier IASI; Spectral range of approximately 3.6–15.5 μm; 0.25 cm⁻¹ spectral resolution; Approximately 12 km individual sounding pixels; Nearly global coverage, normally twice daily; Improved temperature and humidity profiling near the surface; and Detection of ozone, methane, carbon dioxide, sulphur dioxide, aerosols and dust.
It is especially valuable for numerical weather prediction, tropical-cyclone environments, heatwaves, atmospheric rivers, volcanic emissions and long-term climate monitoring. Its first spectra were received in September 2025, followed by staged calibration, validation and product release during 2026. EUMETSAT’s IASI-NG first-data report provides the current mission description.
HIRAS-II on FY-3H – China
FY-3H was launched in September 2025 and is currently undergoing instrument testing. Its HIRAS-II provides: Approximately 3,053 channels; Spectral coverage from about 3.92 to 15.38 μm; 0.625 cm⁻¹ spectral resolution; 14 km spatial resolution; and A swath approximately 2,300 km wide.
It supports global temperature and humidity profiling, ozone and greenhouse-gas monitoring and numerical weather prediction. Earlier HIRAS-II instruments on FY-3E and FY-3F are already operational. Official HIRAS-II specifications give further details.
Sentinel-4 and Sentinel-5
These are atmospheric-composition imaging spectrometers rather than broad surface-imaging systems.
- Sentinel-4, hosted on MTG-S1, observes Europe and part of North Africa every hour at about 8 km resolution. It measures nitrogen dioxide, ozone, sulphur dioxide, formaldehyde and aerosols. This supports monitoring of urban pollution, wildfire smoke, dust and volcanic emissions. ESA Sentinel-4
- Sentinel-5A, hosted on Metop-SG-A1, provides daily global coverage in seven spectral bands from ultraviolet through shortwave infrared. It targets ozone, NO₂, SO₂, formaldehyde, glyoxal, CO, methane, aerosols and UV radiation. Its product rollout follows calibration and commissioning. ESA Sentinel-5 first observations
- Latest surface, vegetation, ocean and emissions sensors
Mission/sensor | Important specifications | Main hazard-related applications |
EnMAP | About 224 usable bands; 420–2,450 nm; 30 m pixels; 30 km swath; target revisit under four days with pointing | Drought, crop stress, soil degradation, burn severity, landslide materials, inland/coastal water quality |
NASA EMIT | 285 bands; 381–2,493 nm; about 7.5 nm spectral resolution; 60 m pixels; operating from the ISS through at least 2026 | Mineral-dust sources, methane and CO₂ plumes, snow impurities, vegetation and hydrology |
Tanager-1 | Approximately 424–426 bands; about 400–2,500 nm; 30 m pixels; 18 km swath | Facility-scale methane and CO₂ emissions, vegetation, minerals and environmental contamination |
PACE OCI | More than 200 hyperspectral wavelengths from UV to NIR, plus discrete SWIR bands; approximately 1.2 km; near-global coverage every 1–2 days | Harmful algal blooms, phytoplankton composition, water quality, aerosols, dust and wildfire smoke |
FLEX/FLORIS | Scheduled launch 15 September 2026; 500–780 nm; 300 m pixels; 150 km swath | Direct observation of photosynthetic activity, drought and heat stress, crop and ecosystem health |
EnMAP’s current technical specifications are available from DLR. EMIT’s extended mission provides 285-band data at 60 m resolution through at least 2026, according to NASA Earthdata. Tanager-1 combines a NASA-designed imaging spectrometer with a commercial satellite and has already detected facility-scale gas plumes; see NASA JPL and Tanager specifications.
PACE is currently the most advanced global polar-orbiting ocean-colour hyperspectral sensor, recording more than 200 wavelengths for phytoplankton and aquatic-hazard analysis. NASA’s 2026 PACE update describes its current performance.
FLEX is scheduled to launch in September 2026. Its FLORIS spectrometer will measure the faint fluorescence emitted during photosynthesis, providing a more direct indicator of vegetation function than conventional greenness indices. ESA FLEX mission
- Multi-hazard detection capabilities
Hazard | Contribution from hyperspectral sensing | Essential complementary observations |
Extreme precipitation and severe convection | Temperature–humidity profiles, precipitable water, instability indices, moisture convergence, cloud phase and pre-convective environment | GPM/FY-3G precipitation radar, microwave radiometers, geostationary imagery, lightning, weather radar and rain gauges |
Tropical cyclones | Atmospheric thermal and moisture structure, dry-air intrusion, upper-level instability and trace-gas/aerosol environment | Scatterometer winds, microwave rain and ice, SAR, altimetry, ocean heat content and forecast models |
Floods and flash floods | Daytime surface-water classification, sediment, turbidity, contamination and post-flood vegetation effects | SAR for cloud-penetrating flood extent, rainfall estimates, river gauges, DEMs and hydrological models |
Drought, heat and agricultural stress | Chlorophyll, pigments, canopy water, cellulose, lignin, photosynthetic stress and soil properties | Thermal land-surface temperature, evapotranspiration, microwave soil moisture and seasonal forecasts |
Wildfires | Fuel and vegetation stress, smoke composition, gas emissions, burn severity and ecological recovery | MWIR/TIR active-fire detection, geostationary rapid imagery, wind forecasts and ground fire reports |
Landslides | Clay and mineral composition, vegetation stress, soil disturbance and post-event scars | Rainfall, soil moisture, DEM, Sentinel-1/NISAR InSAR deformation and ground-slope monitoring |
Volcanoes | SO₂ and ash composition, thermal/mineral characteristics and hydrothermal alteration | InSAR deformation, thermal hotspots, seismicity, GNSS and ground gas measurements |
Earthquakes | Post-event surface disruption and environmental damage; sometimes fault-zone mineral mapping | Seismic networks and InSAR displacement; hyperspectral imagery cannot predict earthquake occurrence |
GLOFs and snow/ice hazards | Snow grain size, snow impurities, ice-albedo changes, exposed moraine and lake-water properties | SAR, optical imagery, altimetry, glacier velocity, lake-level sensors, DEMs and downstream gauges |
Dust, smoke and air pollution | Mineral source composition, aerosols, NO₂, SO₂, ozone, formaldehyde, CO, methane and CO₂ | Wind fields, lidar, surface air-quality stations and atmospheric-transport models |
Harmful algal blooms and water pollution | Phytoplankton pigments, chlorophyll, suspended sediment, coloured dissolved material and some pollutants | Water sampling, buoys, temperature, currents and public-health thresholds |
Oil spills and marine pollution | Spectral differentiation of oil, water and affected vegetation under suitable illumination | SAR for all-weather/night detection, vessel tracking and field confirmation |
Tsunamis and coastal inundation | Primarily post-event inundation, sediment and ecosystem-damage assessment | Seismic networks, GNSS, deep-ocean buoys, tide gauges, radar altimetry and coastal models |
Extreme-precipitation example
For extreme rainfall, the correct detection chain is:
- Hyperspectral sounder: detects moisture, temperature, instability and atmospheric layers capable of supporting deep convection.
- Geostationary imager: observes cloud growth, cloud-top cooling, overshooting tops and storm motion.
- Lightning imager: detects rapid increases in electrical activity associated with storm intensification.
- Microwave imager and precipitation radar: measure hydrometeors, rainfall intensity and the storm’s three-dimensional precipitation structure.
- SAR and hydrological observations: map flooding, saturated land and affected infrastructure.
- Forecast and impact model: combines hazard intensity with people, settlements, roads, crops and critical facilities.

NASA’s GPM Core Observatory combines a microwave imager with dual-frequency precipitation radar to measure the internal structure of storms and precipitation. It therefore measures rainfall more directly than a hyperspectral infrared sounder. NASA GPM mission
- Recommended multi-hazard early-warning architecture
A practical national architecture should contain four observation layers:
- Continuous geostationary layer: atmospheric profiles, rapid cloud imagery and lightning.
- All-weather layer: SAR, microwave soil moisture, precipitation radar and scatterometer winds.
- High-resolution environmental layer: hyperspectral, multispectral, thermal, DEM and altimetry.
- Ground layer: weather radar, AWS, rain and river gauges, seismic/GNSS stations, air-quality monitors and community observations.
NISAR is a major new complementary capability. It entered its science phase and released provisional L-band data in July 2026. Its L- and S-band radar observations support flood mapping, soil moisture, glacier movement and centimetre-scale surface deformation associated with earthquakes, volcanoes and landslides. NASA NISAR mission
- Priorities for Bangladesh and South Asia
For Bangladesh and neighbouring countries, the most immediately useful combination is:
- FY-4B GIIRS, AGRI and high-speed imagery from 105°E;
- FY-4C data as it completes commissioning;
- Himawari-8/9 and INSAT-3DS imagery;
- FY-3, NOAA and Metop polar atmospheric sounders;
- GPM and FY-3G precipitation measurements;
- Sentinel-1 and NISAR radar for flood, erosion, subsidence and landslide monitoring;
- Sentinel-2 and Landsat for high-resolution exposure and damage mapping;
- EnMAP, EMIT and PACE for environmental, agricultural and water-quality analysis;
- Weather radar, rainfall and river gauges for calibration and warning thresholds; and
- AI-supported data fusion linked to impact-based forecasting and Common Alerting Protocol dissemination.
The central conclusion is that hyperspectral sensing should be treated as a high-value analytical layer within a multi-sensor early-warning architecture—not as a replacement for radar, microwave, hydrological, seismic or community-based monitoring systems.
Near-term advances include FLEX in September 2026 and the planned Copernicus CHIME hyperspectral satellites, currently targeted for 2028 and 2030. CHIME is designed to provide routine 30 m hyperspectral observations across approximately 400–2,500 nm for agriculture, soils, biodiversity, water and natural-resource monitoring. Copernicus CHIME mission status
Extreme precipitation detection from satellites
The following analysis details the technologies, specific data products, and known limitations involved in this process.
1. The Physics of Detection: How Satellites “See” Heavy Rain
Satellites use two primary parts of the electromagnetic spectrum to detect precipitation. Understanding the difference is key to interpreting the data.
A. Passive Microwave (The “X-Ray”)
This is the most accurate method for detecting heavy rain. Raindrops and ice particles interact strongly with microwave energy.
B. Infrared (The “Cloud Top” Proxy)
Geostationary (GEO) satellites sit approx. 36,000 km above the Earth and stare continuously at the same spot.4
2. The “Gold Standard” Products
To solve the trade-off between LEO accuracy and GEO frequency, modern systems use constellations. They combine accurate microwave “snapshots” from LEO satellites and fill in the time gaps using GEO infrared data.
| Product | Full Name | Strength for Extremes | Weakness |
| IMERG | Integrated Multi-sat Retrievals for GPM | The global standard. Calibrated by the GPM Core Observatory radar. Excellent for global coverage. | Tends to underestimate peak extreme intensities due to averaging (smoothing) algorithms. |
| GSMaP | Global Satellite Mapping of Precipitation | Often performs better in identifying orographic (mountain) heavy rain due to specific orographic correction algorithms. | Can have higher false alarm rates in some regions compared to IMERG. |
| CMORPH | CPC Morphing Technique | Uses microwave data primarily and “morphs” (moves) the precipitation features using wind vectors derived from GEO satellites. | struggles when microwave gaps are too long; purely morphing can miss rapid storm intensification. |
3. Why Satellites Struggle with “Extreme” Events
While satellites are excellent at measuring accumulated rainfall over a month, they frequently struggle with instantaneous extreme events (e.g., flash floods).
4. Advanced Detection Techniques
To improve detection of extremes, scientists are moving beyond simple brightness temperature thresholds:
Summary Recommendation
Extreme precipitation detection from satellites
Latest Hyperspectral Sensors Enable Extreme-Precipitation Detection from Satellites
It features the newly commissioned MTG-S1 Infrared Sounder and accurately combines hyperspectral atmospheric profiling with microwave and dual-frequency radar precipitation measurements. Scientific basis: ESA MTG-S1 Infrared Sounder and NASA GPM precipitation sensors.
Hyperspectral: The New Standard in Extreme Precipitation Detection
The frontier of satellite-based precipitation detection is the transition from multispectral to hyperspectral sensing. While multispectral sensors use a few broad bands to capture images, hyperspectral sensors use hundreds of narrow, contiguous bands (see Image 5 for a detailed comparison). This “continuous spectrum” approach provides unique, high-fidelity signatures that significantly enhance the detectability of extreme events. The main breakthrough is in the use of new Hyperspectral Microwave Sounders (HyMS).
HyMS can peer through clouds, which are essential for looking at extreme convective storms. Key advantages of this new technology include:
Superior Sensitivity to Atmospheric Profiles: Unlike traditional sounders, HyMS can resolve fine details in the spectral signatures of water vapor, temperature, and, critically, different cloud ice types and sizes. This ability to “dissect” the vertical structure of a storm provides a direct measure of its intensity and microphysical processes, which are foundational for accurate precipitation rates (extending the capabilities of GPM, as detailed in Image 2).
High-Frequency LEO Constellations: The use of small-satellite and CubeSat technology (e.g., NASA TROPICS and commercial demonstrators like Spire’s HyMS) allows for the deployment of dense LEO constellations. This dramatically increases the temporal resolution making a “GPM-like” observation available much more frequently, approaching the temporal resolution of GEO satellites for detecting rapid onset, small-scale convective events.
Advanced Data Fusion (IMERG-Next): Integrating these high-fidelity hyperspectral datasets into the next generation of algorithms, like ‘IMERG-NEXT,‘ enables unprecedented accuracy. These systems, often using onboard AI, can combine GEO IR convective imagery (Image 1) with LEO references (Image 2) and the new high-fidelity HyMS soundings to pinpoint precipitation rates and types (e.g., distinguishing extreme rain from large hail or heavy graupel) at a sub-kilometer resolution and with a significant boost to early warning lead times (see Image 5).
Integrating Hyperspectral Data into Extreme Precipitation Systems
This detailed technical illustration acts as a definitive continuation of the data fusion narrative established in Image 3. The top section, ‘THE NEW GAME CHANGER: HYPERSPECTRAL MICROWAVE SOUNDING,‘ is a detailed diagram that contrasts a traditional ‘SINGLE BROADBAND CHANNEL’ sounder with the new ‘HUNDREDS OF NARROW CONTIGUOUS CHANNELS’ from a new ‘HYPERSPECTRAL MICROWAVE SOUNDER (HyMS) DEMONSTRATOR.‘ A spectral signature graph, ‘ATMOSPHERIC MICROWAVE EMISSIVITY,‘ illustrates how these channels uniquely resolve WATER VAPOR (H2O), OXYGEN (O2), AND CLOUD ICE SCATTERING. The bottom section shows this new data integrated into an advanced ‘IMERG-NEXT’ algorithm, which incorporates ‘ONBOARD AI’ and ‘PC-SCORE ASSIMILATION’ to produce a highly refined ‘ENHANCED EXTREME EVENT DETECTION & TYPE PINPOINTING’ product, providing detailed information on the specific precipitation type (e.g., HEAVY GRAUPEL) and an improved rain rate at a resolution that gives an additional +6 HOURS of warning lead time.
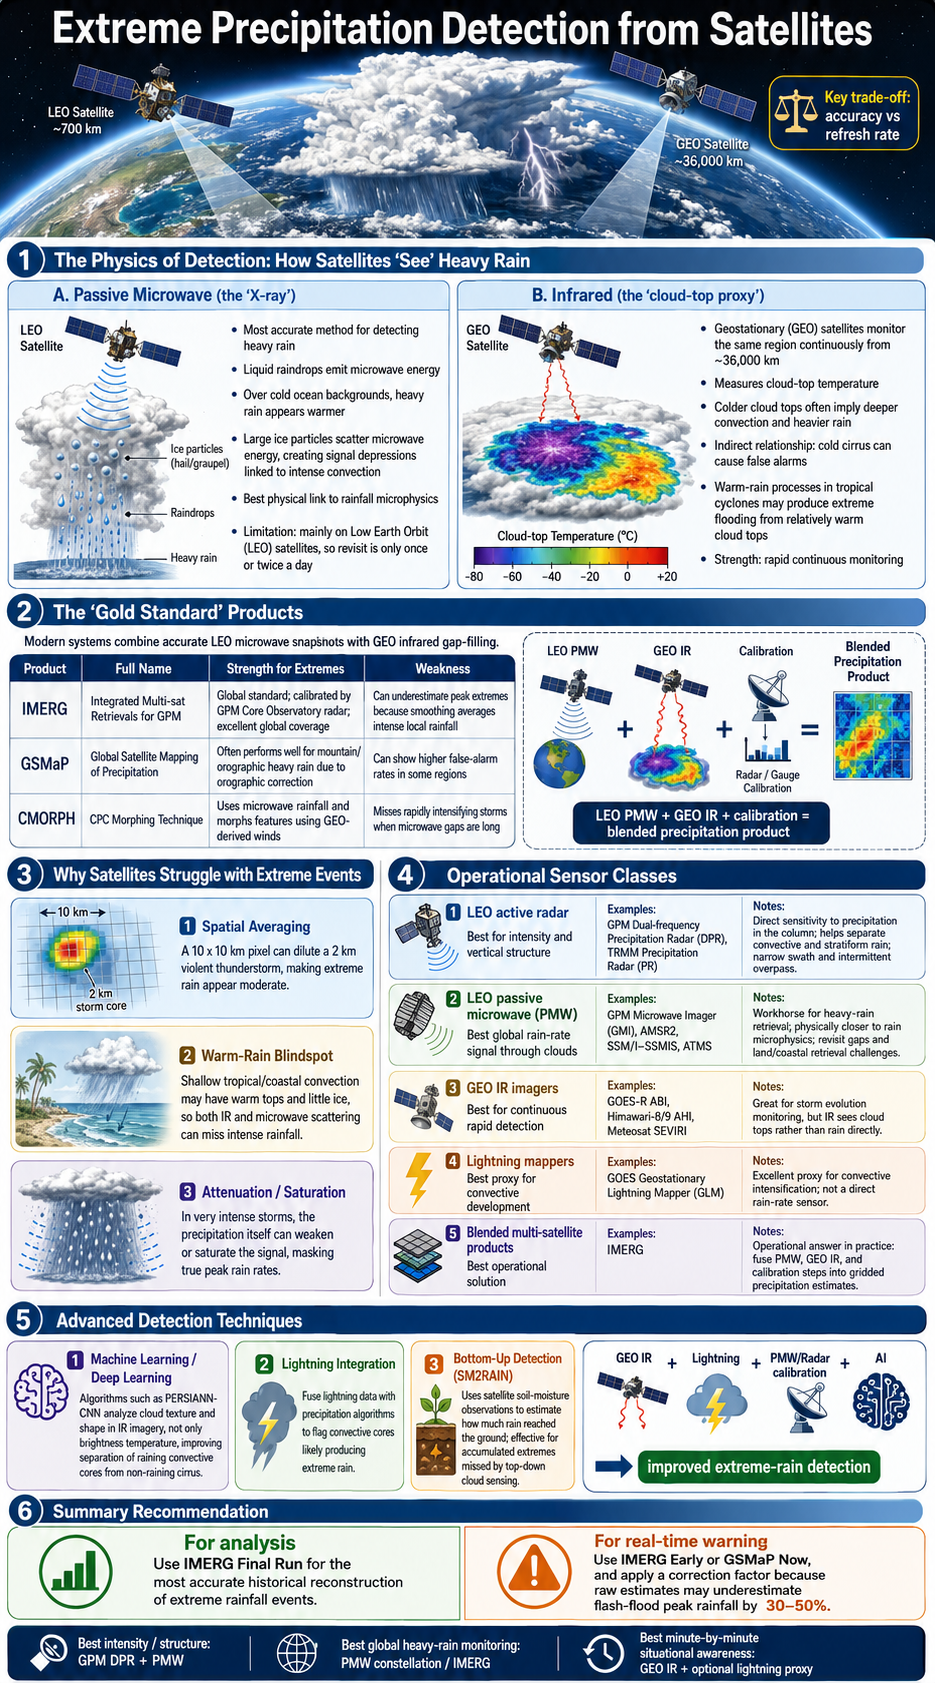
1) Low Earth Orbit (LEO) active radar: best for “how intense and where in the column”
Primary sensor type: Spaceborne precipitation radar
2) LEO passive microwave (PMW): best global “rain-rate signal” through clouds (but with gaps in time)
Primary sensor type: Microwave imagers/sounders used in precipitation retrieval (the workhorse for global heavy rain detection)
Examples:
Strengths for extremes: PMW is physically closer to precipitation microphysics than IR cloud-top methods; strong basis for detecting/quantifying intense rain.
Limits: revisit gaps (hours), coastal/orographic complexities, and retrieval challenges over land for certain regimes.
3) Geostationary (GEO) IR imagers: best for continuous monitoring and “rapid detection,” weaker for true intensity
Primary sensor type: Visible/IR multi-spectral imagers providing rapid-refresh cloud-top observations 4) Lightning mappers: powerful proxy for convective intensification (not rain rate) If your goal is operational extreme-rain monitoring (rather than instrument-level science), you typically use a fusion product such as: Where ML/AI fits (if you are building an extreme-rain detector) A common modern pattern is GEO IR (+ lightning) → calibrated against PMW/radar, using deep learning to improve detection skill and reduce false alarms; this is an active line of operational development for GOES-style precipitation retrieval enhancement. A flash flood detection system is operationally effective when it combines: (1) high-frequency rainfall estimation/nowcasting, (2) fast hydrologic response modeling at small-basin scale, and (3) clear, standardized warning products and dissemination. Globally, the World Meteorological Organization’s Flash Flood Guidance System (FFGS) is an established reference implementation for building national/regional capacity for flash flood warnings. 1) Core system architecture A. Observations and rainfall estimation layer Use the best available mix (in priority order): Output: gridded rain rate and accumulations at multiple durations (e.g., 15/30/60/180 minutes). B. Basin-scale hydrologic detection/forecasting layer Two widely used operational concepts: A concrete example is NOAA/NSSL’s FLASH system, built to improve flash flood warning specificity; it uses the CREST hydrologic model and produces high-resolution, rapidly updated hydrologic fields (soil moisture/streamflow) to support warnings. Output: basin/stream-segment “threat” scores, exceedance probabilities, and short-fuse forecasts. C. Impact and prioritization layer (what matters, where) Flash flood detection becomes much more actionable when converted to impact-based outputs:
Examples/products:Flash flood detection system (end-to-end design)
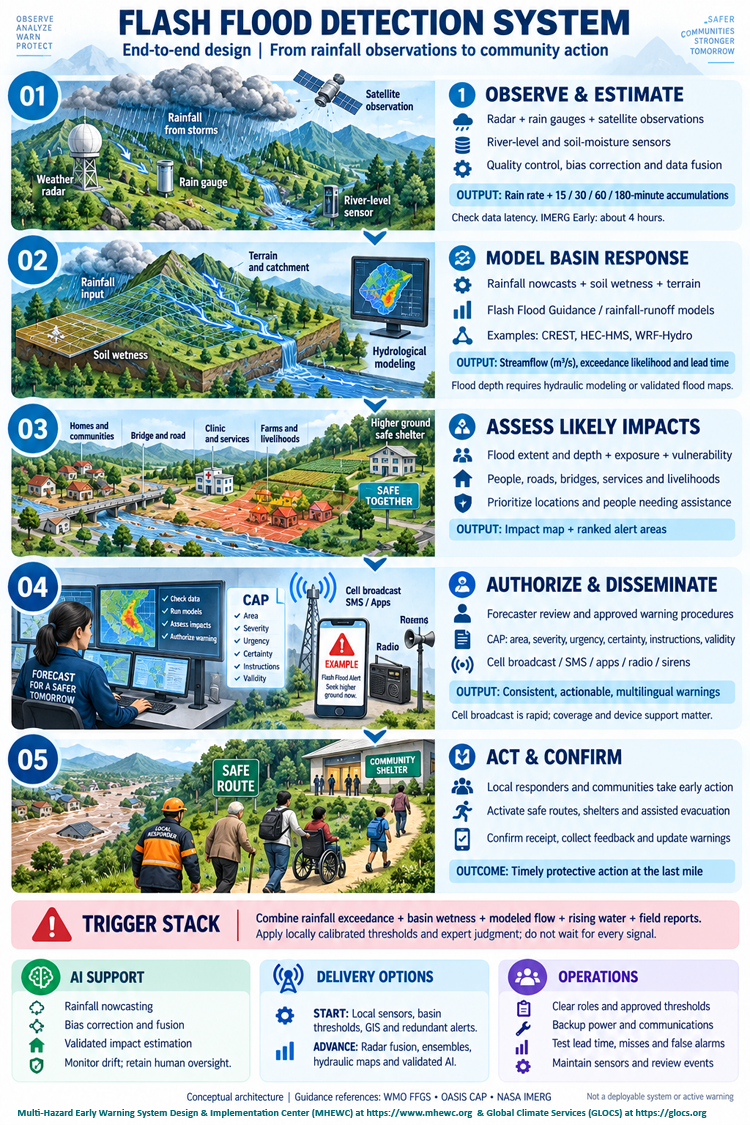
Output: ranked alert list + map of potential impacts. D. Warning generation and dissemination layer Adopt a standards-based alert object so the same warning can be broadcast across multiple channels (SMS, cell broadcast, apps, radio/TV crawlers, sirens, CAP feeds). The Common Alerting Protocol (CAP) is the widely used all-hazards standard for this purpose. Output: CAP alerts with polygon/area, severity/urgency/certainty, guidance text, and validity time. 2) Detection logic (recommended “trigger stack”) A robust flash flood detector should not rely on a single signal. A practical trigger stack is: This mirrors how operational “guidance” systems (FFG/FFGS-style) are intended to translate rainfall into small-basin flood threat. 3) Where AI/ML improves performance (without replacing physics) AI typically adds the most value in three modules: A) Rainfall nowcasting (0-3 hours) Spatiotemporal ML models improve short-lead detection of convective bursts that drive flash floods, especially when fused with radar + satellite. B) Bias correction / data fusion ML post-processing to: C) Learned impact models Supervised models that map “hazard + basin state + exposure” to likely impacts (road flooding probability, affected population), trained on historical events. For operational credibility, keep ML “bounded” (monitor drift, enforce physical constraints where possible, and require human-in-the-loop sign-off for high-severity warnings). 4) Minimum viable vs advanced implementation Minimum viable (works almost anywhere): Advanced (higher skill, lower false alarms): 5) Operational essentials (often neglected) Interagency workflow: forecaster ↔ disaster management ↔ local responders (FFGS emphasizes operational capacity-building and coordination). Threshold governance: who sets/approves thresholds per basin and how updates happen after events Verification: event-based scoring (POD/FAR/CSI by threshold and lead time) and post-event reviews Redundant communications: CAP + non-digital fallbacks for high-risk communities Model: 2 Designing an end-to-end flash flood detection system requires bridging the gap between meteorological observation (what is happening in the sky) and hydrological impact (what happens on the ground), and then successfully communicating that risk to the “last mile.” Below is a technical architectural design for such a system, focusing on latency reduction and high-precision monitoring. Phase 1: Multi-Sensor Data Ingestion (The “Eyes”) Flash floods occur too quickly for any single sensor to capture perfectly. The system must ingest a “constellation” of data sources into a central Data Hub. Data Source Specific Technology/Product Role in Flash Flood Detection Satellite (Precipitation) GPM (IMERG Early) or GSMaP_NRT Provides the broad spatial view. Correction: Must be bias-corrected in real-time using ground gauges. Satellite (Lightning) GOES-GLM or MTG-LI Critical Proxy: Lightning frequency correlates strongly with vertical updraft velocity. A sudden “lightning jump” is often the earliest precursor to the extreme rainfall rates that cause flash floods. Ground Radar X-Band or C-Band If available, offers the highest resolution for calculating quantitative precipitation estimation (QPE). IoT Sensors Ultrasonic Level Sensors & Soil Moisture “Ground truthing.” Soil moisture data (saturation level) determines if the ground will absorb the rain or immediately produce runoff. Phase 2: The Processing Core (The “Brain”) This is where the raw data is converted into actionable intelligence. This requires a High-Performance Computing (HPC) environment or a scalable Cloud Cluster. Instead of warning “50mm of rain expected,” the system calculates impact. Phase 3: Alert Generation & Dissemination (The “Voice”) Speed is critical. The system must bypass congestion. The “Brain” outputs a CAP-formatted message (XML). This standard ensures all downstream systems (Sirens, TV, Mobile) understand the severity, location (polygon), and instruction. System Architecture Diagram To visualize how these components connect, here is the architectural flow: Summary of Logic Flow HEC‑RAS Hydrologic Engineering Center’s River Analysis System is a free hydraulic-modelling platform developed by the US Army Corps of Engineers. It simulates how water moves through rivers, floodplains, urban areas, hydraulic structures and reservoirs. Its results support flood-hazard mapping, infrastructure design, emergency planning, impact-based forecasting and early action. Flood modeling with HEC-RAS involves simulating how water moves through rivers, channels, floodplains and hydraulic structures to estimate the location, depth, velocity and timing of flooding. Developed by the United States Army Corps of Engineers, the Hydrologic Engineering Center’s River Analysis System (HEC-RAS) supports river hydraulics, flood inundation analysis and the assessment of flood-management measures. Its outputs provide an analytical basis for infrastructure design, land-use planning, emergency preparedness and flood early warning. hec.usace.army.mil The practical value of flood modeling is its ability to translate a specified flow or rainfall scenario into a spatial understanding of flooding. This allows planners to investigate which areas could become inundated, how conditions may develop over time, and where protective measures could change flood behavior. HEC-RAS often receives river-flow hydrographs from observations or a rainfall-runoff model such as HEC-HMS. A hydrograph describes how discharge changes over time. HEC-HMS can simulate watershed processes that generate runoff, while HEC-RAS calculates how the resulting water moves through the river and floodplain. HEC-RAS also supports direct precipitation and infiltration modeling, including rainfall applied across a two-dimensional modeling area, commonly called rain-on-grid. The approach should match the catchment, available data and study objectives. The choice of model configuration depends on the flow pathways that need to be represented: HEC-RAS supports all three configurations. The appropriate choice balances hydraulic complexity, data quality, computational demand and the decisions the model must support. The time dimension also matters. Steady-flow analysis examines conditions for specified flows, while unsteady-flow analysis represents changing flows and water levels through an event. Unsteady modeling is needed to investigate flood-wave movement, overtopping sequences and changes in inundation over time. A practical modeling workflow should connect the following stages: Define the decisions and study boundaries. Establish whether the model will support floodplain mapping, bridge assessment, embankment design, evacuation planning or operational forecasting. Specify the river reaches, floodplain areas, scenarios and locations where reliable results are required. These choices determine the necessary surveys, model detail and acceptable uncertainty. Develop an accurate terrain and river representation. Assemble elevation data, river cross-sections and channel bathymetry, meaning the shape and elevation of the submerged riverbed. Check coordinate systems, vertical reference levels, units and survey dates. Examine whether the terrain captures channels, banks, embankments and other features that control water movement. HEC guidance specifically emphasizes checking channel representation and, where necessary, combining channel data with floodplain terrain. Represent structures, surface resistance and flow pathways. Include relevant bridges, culverts, weirs, levees and other hydraulic controls. Assign Manning’s roughness coefficients to represent resistance associated with channels, vegetation and land cover. In a 2D model, use mesh refinement and breaklines to align cell boundaries with important features such as raised roads and embankments. Their representation can substantially influence where flooding occurs. Specify inflows, downstream conditions and the initial state. Provide upstream and tributary hydrographs, relevant lateral inflows, and downstream conditions such as water-level hydrographs or an appropriate outflow relationship. Establish initial water levels and flows. For direct rainfall modeling, prepare precipitation and infiltration inputs and clearly allocate contributing areas so runoff is accounted for consistently. Select suitable equations and computational settings. HEC-RAS offers diffusion-wave and shallow-water equation options for 2D modeling. Rapidly changing flood waves, including many flash-flood and dam-breach cases, require the momentum processes represented by the shallow-water equations. Mesh size and computational time step should be tested together because they affect both numerical stability and accuracy. A finer mesh should be justified by the hydraulic features and results being investigated. Calibrate, validate and examine uncertainty. Calibration adjusts physically reasonable parameters to improve agreement with observed conditions. Compare modeled results with available water levels, high-water marks, flood timing and inundation evidence. The assessment should reserve separate events for validation where records permit, report discrepancies, and test sensitivity to uncertain inputs. Useful tests include variations in inflow, roughness, terrain, structure assumptions, mesh resolution and time step. Where observations are limited, document the resulting limits on confidence. The resulting hydraulic products can then be interpreted for practical decisions. The applications below are examples of how model outputs can inform planning: RAS Mapper supports these outputs, with availability depending on the simulation. Arrival-time and duration products require explicit thresholds and time references; events with multiple flood peaks also warrant examination of the full time series. hec.usace.army.mil Connecting hydraulic outputs with exposure and vulnerability is the next step toward flood-risk assessment. A practical implementation would overlay inundation results with population, buildings, roads, health facilities, schools, water systems, agricultural land and critical services. It would then apply locally appropriate vulnerability information to assess likely consequences. For example, flooding of a road may interrupt access to a hospital even when the hospital itself remains dry. This requires examining transport connections and service dependencies alongside direct inundation. For an impact-based flood early warning programme, a suitable implementation would connect updated observations and forecasts to the model, translate the hydraulic results into potential impacts, and submit the products through agreed technical review and warning-authorization procedures. Precomputed inundation scenarios can support rapid interpretation where running a detailed model during every forecast cycle would take too long. Their use should account for differences in tributary flows, downstream levels and other conditions that influence flooding. Operational design should also evaluate whether the information arrives early enough to support action. The usable warning period must accommodate data transmission, forecast production, model execution, technical review, communication and community response. Warning thresholds should therefore be developed around locally relevant consequences and the time required to act. For a complete assignment, the deliverables should include the reusable HEC-RAS model, documented input datasets, calibration and validation findings, scenario-based flood maps, uncertainty information and a technical report explaining appropriate uses. Where early warning is an objective, the package should also include forecast-input procedures, agreed impact thresholds, responsibilities for updating the model, staff training and operating procedures for producing and reviewing warning information. HEC‑RAS transforms rainfall, river-flow or water-level information into hydraulic flood characteristics: These outputs become risk or impact information only after they are combined with exposure and vulnerability data—for example, population, settlements, roads, hospitals, crops, livelihoods and critical infrastructure. Modelling approach Most appropriate application 1D steady flow Design-flood profiles, water levels for fixed discharges and relatively confined river channels 1D unsteady flow Movement of a flood hydrograph through a river network over time 2D unsteady flow Floodplains, urban flooding, flash floods, coastal flooding, multiple flow paths and complex topography Coupled 1D–2D Efficient simulation of a defined river channel in 1D and surrounding floodplain in 2D Rain-on-grid/rain-on-mesh Direct application of spatial rainfall over a 2D domain to simulate runoff and surface-water movement Dam/levee breach Breach formation, flood-wave propagation, arrival time and downstream hazard mapping HEC‑RAS supports one-dimensional, two-dimensional and combined 1D–2D unsteady hydraulic modelling. Official HEC‑RAS capabilities For basin-scale river flooding, a common arrangement is: HEC‑RAS can also apply spatially varying rainfall directly and represent infiltration through SCS Curve Number, Deficit-and-Constant, or Green–Ampt methods. USACE precipitation and infiltration guidance Terrain and river geometry A surface DEM frequently represents the top of vegetation, buildings or bridges rather than the true ground or channel bed. Therefore, terrain must be corrected and supplemented with surveyed bathymetry where possible. Hydrological and meteorological data Surface characteristics Calibration and validation observations Step 1: Define the modelling objective Clearly determine whether the model will support: The objective determines the model extent, resolution, scenarios and acceptable uncertainty. Step 2: Prepare and quality-control the terrain All elevation, survey and water-level data must use the same: Datum or unit errors can shift predicted water levels by metres and invalidate the flood map. Step 3: Build the hydraulic geometry For a 1D model, define river reaches, cross-sections, banks, ineffective-flow areas and hydraulic structures. For a 2D model: Cell size should reflect terrain complexity—not simply the finest available DEM resolution. Step 4: Assign roughness and infiltration Develop a spatial Manning’s layer from land cover and adjust it using field observations and calibration. Where rain-on-grid modelling is applied, develop an infiltration layer from land-cover and soil information. RAS Mapper can create infiltration layers using land cover, soils, their intersection or classification polygons. HEC‑RAS infiltration-layer guidance Step 5: Enter boundary and initial conditions Typical conditions include: The downstream boundary should be located sufficiently far from the principal study area to minimize artificial effects. HEC‑RAS boundary-condition guidance Step 6: Configure and run simulations Select: Examine volume-conservation errors, oscillating water levels, unrealistic velocities, wetting-and-drying problems and sudden flow discontinuities. Step 7: Calibrate and validate Calibration should reproduce: Adjust physically defensible parameters such as Manning’s , ineffective-flow areas, structure coefficients and storage representation. Do not use roughness adjustment to compensate for erroneous terrain, discharge or boundary conditions. Calibrate against one or more historical events and validate the model independently against a different event. USACE defines calibration as adjusting model parameters so that observed data are reproduced to acceptable accuracy. USACE calibration guidance Step 8: Run flood scenarios Possible scenarios include: An operational HEC‑RAS-based flood-warning system can follow this chain: The operational platform should produce location-specific answers to: For rapid operations, it is often preferable to precompute a flood-scenario library linking forecast gauge levels or discharges to inundation and impact maps. Real-time forecasts can then select or interpolate the appropriate scenario much faster than running a large model from the beginning. The most frequent causes of unreliable results are: A technically sound HEC‑RAS flood model should therefore be treated as a calibrated decision-support system—not merely as software-generated inundation mapping. Flash floods are among the most devastating natural hazards globally, causing significant loss of life, property damage, and disruption to communities due to their rapid and unpredictable nature . Effective flash flood hazard detection systems are crucial for mitigating these impacts by providing timely warnings and facilitating rapid response actions . These systems integrate various technologies and methodologies, including hydrological models, meteorological data, remote sensing, Geographic Information Systems (GIS), and increasingly, advanced machine learning and artificial intelligence techniques The fundamental principle behind flood forecasting models involves the conservation of mass, partitioning precipitation into quickflow and baseflow based on infiltration-excess or saturation-excess mechanisms . Flood hazard can be quantified as a product of the physical process (hazard), the assets or people in its path (exposure), and their susceptibility to harm (vulnerability) . Components and Methodologies of Flash Flood Detection Systems Flash floods (Cyclone Shaheen) Source: This flowchart illustrates the process of analyzing flash floods associated with Cyclone Shaheen and the Al Azm trough, focusing on data collection, analysis, and evaluation of satellite and ground-observed data . Flash-flood analysis and prediction Source: 15 This figure depicts a comprehensive workflow for flash flood analysis and prediction, involving flash flood case locations, feature construction (e.g., Elevation, Imperviousness), machine learning models (RF&GBDT), prediction of flooded/non-flooded labels, hotspot mapping, and analysis of variable importance using SHAP values, and cross-city similarity for model transferability . Flash-flood susceptibility map This workflow illustrates the creation of a flash-flood susceptibility map using multi-source geospatial data, deep neural networks (TFDNN), and Harris Hawks Optimization (HHO) for weight and bias optimization . Neural network architecture fo… This image depicts a neural network architecture with an input layer of 10 neurons representing environmental factors (e.g., landcover, soil type, rainfall, TWI, elevation, slope, curvature, aspect), three hidden layers with neurons each using ReLU activation, and a single-neuron output layer with a Sigmoid function to generate a flash-flood susceptibility index . Flash-flood Susceptibility Map This flash-flood susceptibility map uses color coding to indicate different levels of susceptibility from “No” to “High”, with pink dots marking flooded locations used for training and black dots for validating the model . An attention mechanism, specifically the convolutional block attention module (CBAM), can enhance CNN models for flash flood susceptibility mapping, addressing issues like gradient explosion and overfitting . Flash flood detection using YO… This figure shows the YOLOv8 model detecting “flash_flood” with high confidence scores in two different video feeds, indicating its application in real-time monitoring . Flood Susceptibility Mapping This flowchart outlines the process of flood susceptibility mapping and analysis, covering data collection, modeling using a hybrid ABC-DNN-LM approach, and flood mapping with accuracy evaluation using ROC and AUC curves . Challenges and Future Directions Despite advancements, challenges remain in flash flood detection. These include the short lead times associated with flash floods, which make accurate forecasting difficult, and the need for more holistic analyses of model uncertainties . Non-identifiability of spatially distributed environmental models further complicates the process . Future research aims to enhance the integration of multidisciplinary approaches, including artificial intelligence, IoT, and cloud computing, for more robust flash flood early warning and susceptibility prediction systems . This also includes improving model interpretability to facilitate trust and understanding among stakeholders . Furthermore, an objective framework for bivariate risk analysis of flash floods under the compound effect of rainfall characteristics is being developed, aiming to classify flash flood events based on intensity and process using clustering methods 34. The use of agent-based models to simulate human responses to flash flood warnings and improve evacuation performance is also an important area of study Designing an end-to-end flash flood detection system requires bridging the gap between meteorological observation (what is happening in the sky) and hydrological impact (what happens on the ground), and then successfully communicating that risk to the “last mile.” ……………………………………………………………………………………………………………………… References ;
Flood Modeling with HEC‑RAS
Configuration How it represents flooding Typical application One-dimensional – 1D Represents flow primarily along a river or channel using cross-sections. River reaches where the dominant flow direction is well defined. Two-dimensional – 2D Represents water moving across a computational mesh in two horizontal directions. Floodplains, branching flow paths and areas where water spreads around terrain features. Combined 1D/2D Connects a 1D river network with 2D floodplain areas and calculates exchanges between them. Larger river systems requiring detailed analysis of selected floodplain areas. 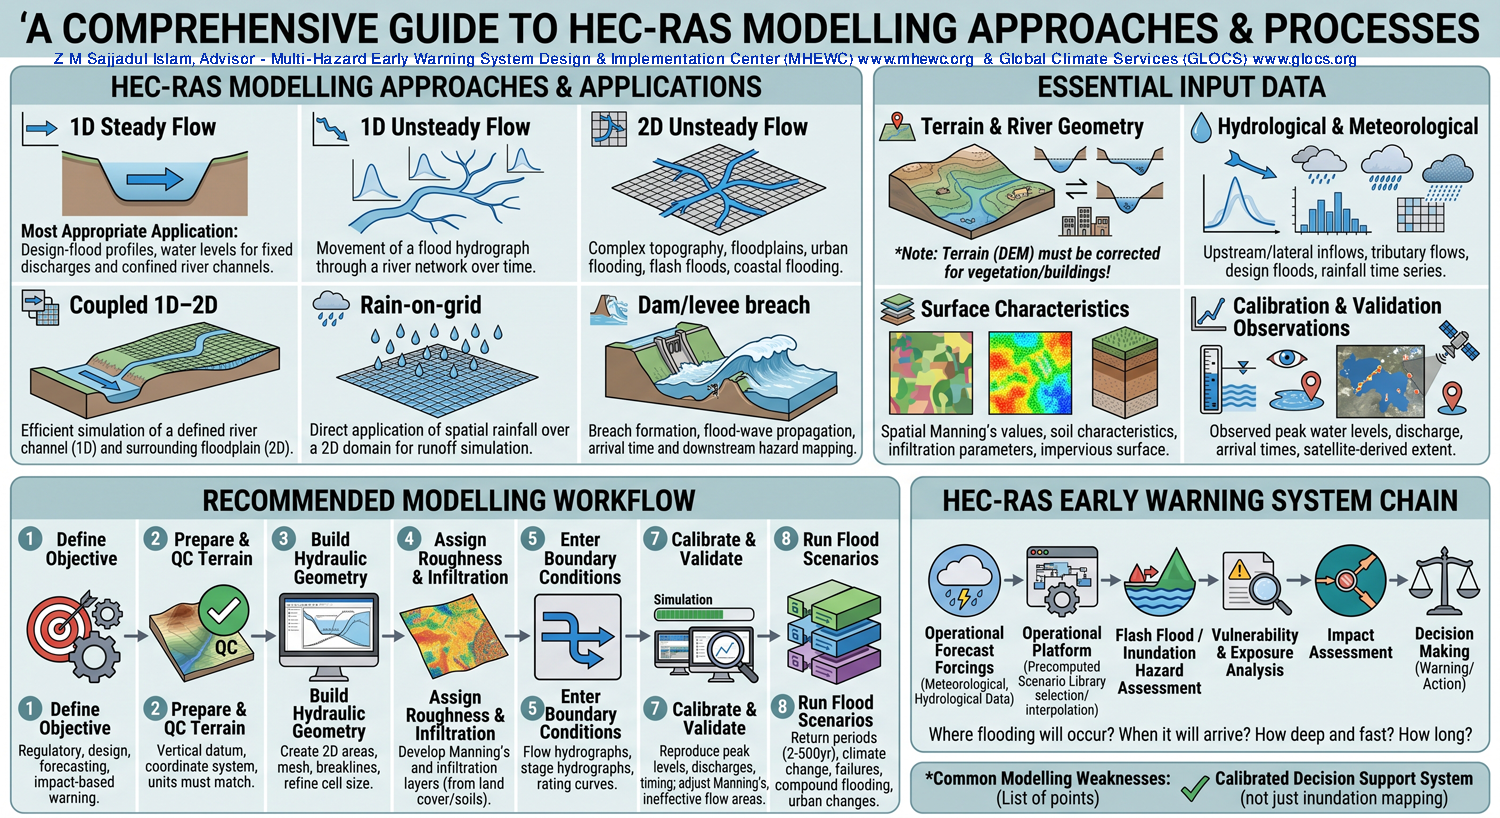
Model output What it describes Example planning use Flood extent The area inundated under a specified scenario. Identify settlements, agricultural areas and infrastructure requiring further assessment. Flood depth Water depth above the modeled ground surface. Assess building exposure and potential disruption of facilities. Water-surface elevation Flood level relative to an elevation reference. Compare modeled levels with bridge decks, embankment crests and facility elevations. Flow velocity The speed of moving water. Identify locations requiring closer assessment of flow hazards. Arrival time When water reaches a specified depth threshold. Support evaluation of warning and evacuation timelines. Duration and recession How long flooding persists and when water recedes. Inform access, service-continuity and recovery planning. Flash flood Detection ( Sample System):


Still need to feed huge amounts of information……….Exploring the most robust ICT system for surface, atmospheric, and sea surface observation, real-time data acquisition, on-the-fly processing, and display in MHEWS for awareness.
[ The copyright © 2026 Z M Sajjadul Islam, Advisor, Multi-Hazard Early Warning System Design and Implementation Center (MHEWC – www.mhewc.org ). All rights reserved. Any material quoted, reproduced, adapted, or extracted from this proposal must be properly cited and attributed to the author. Please call at +8801711979179, Email: zmsajjad@gmail.com ]